EVRCONSULTING
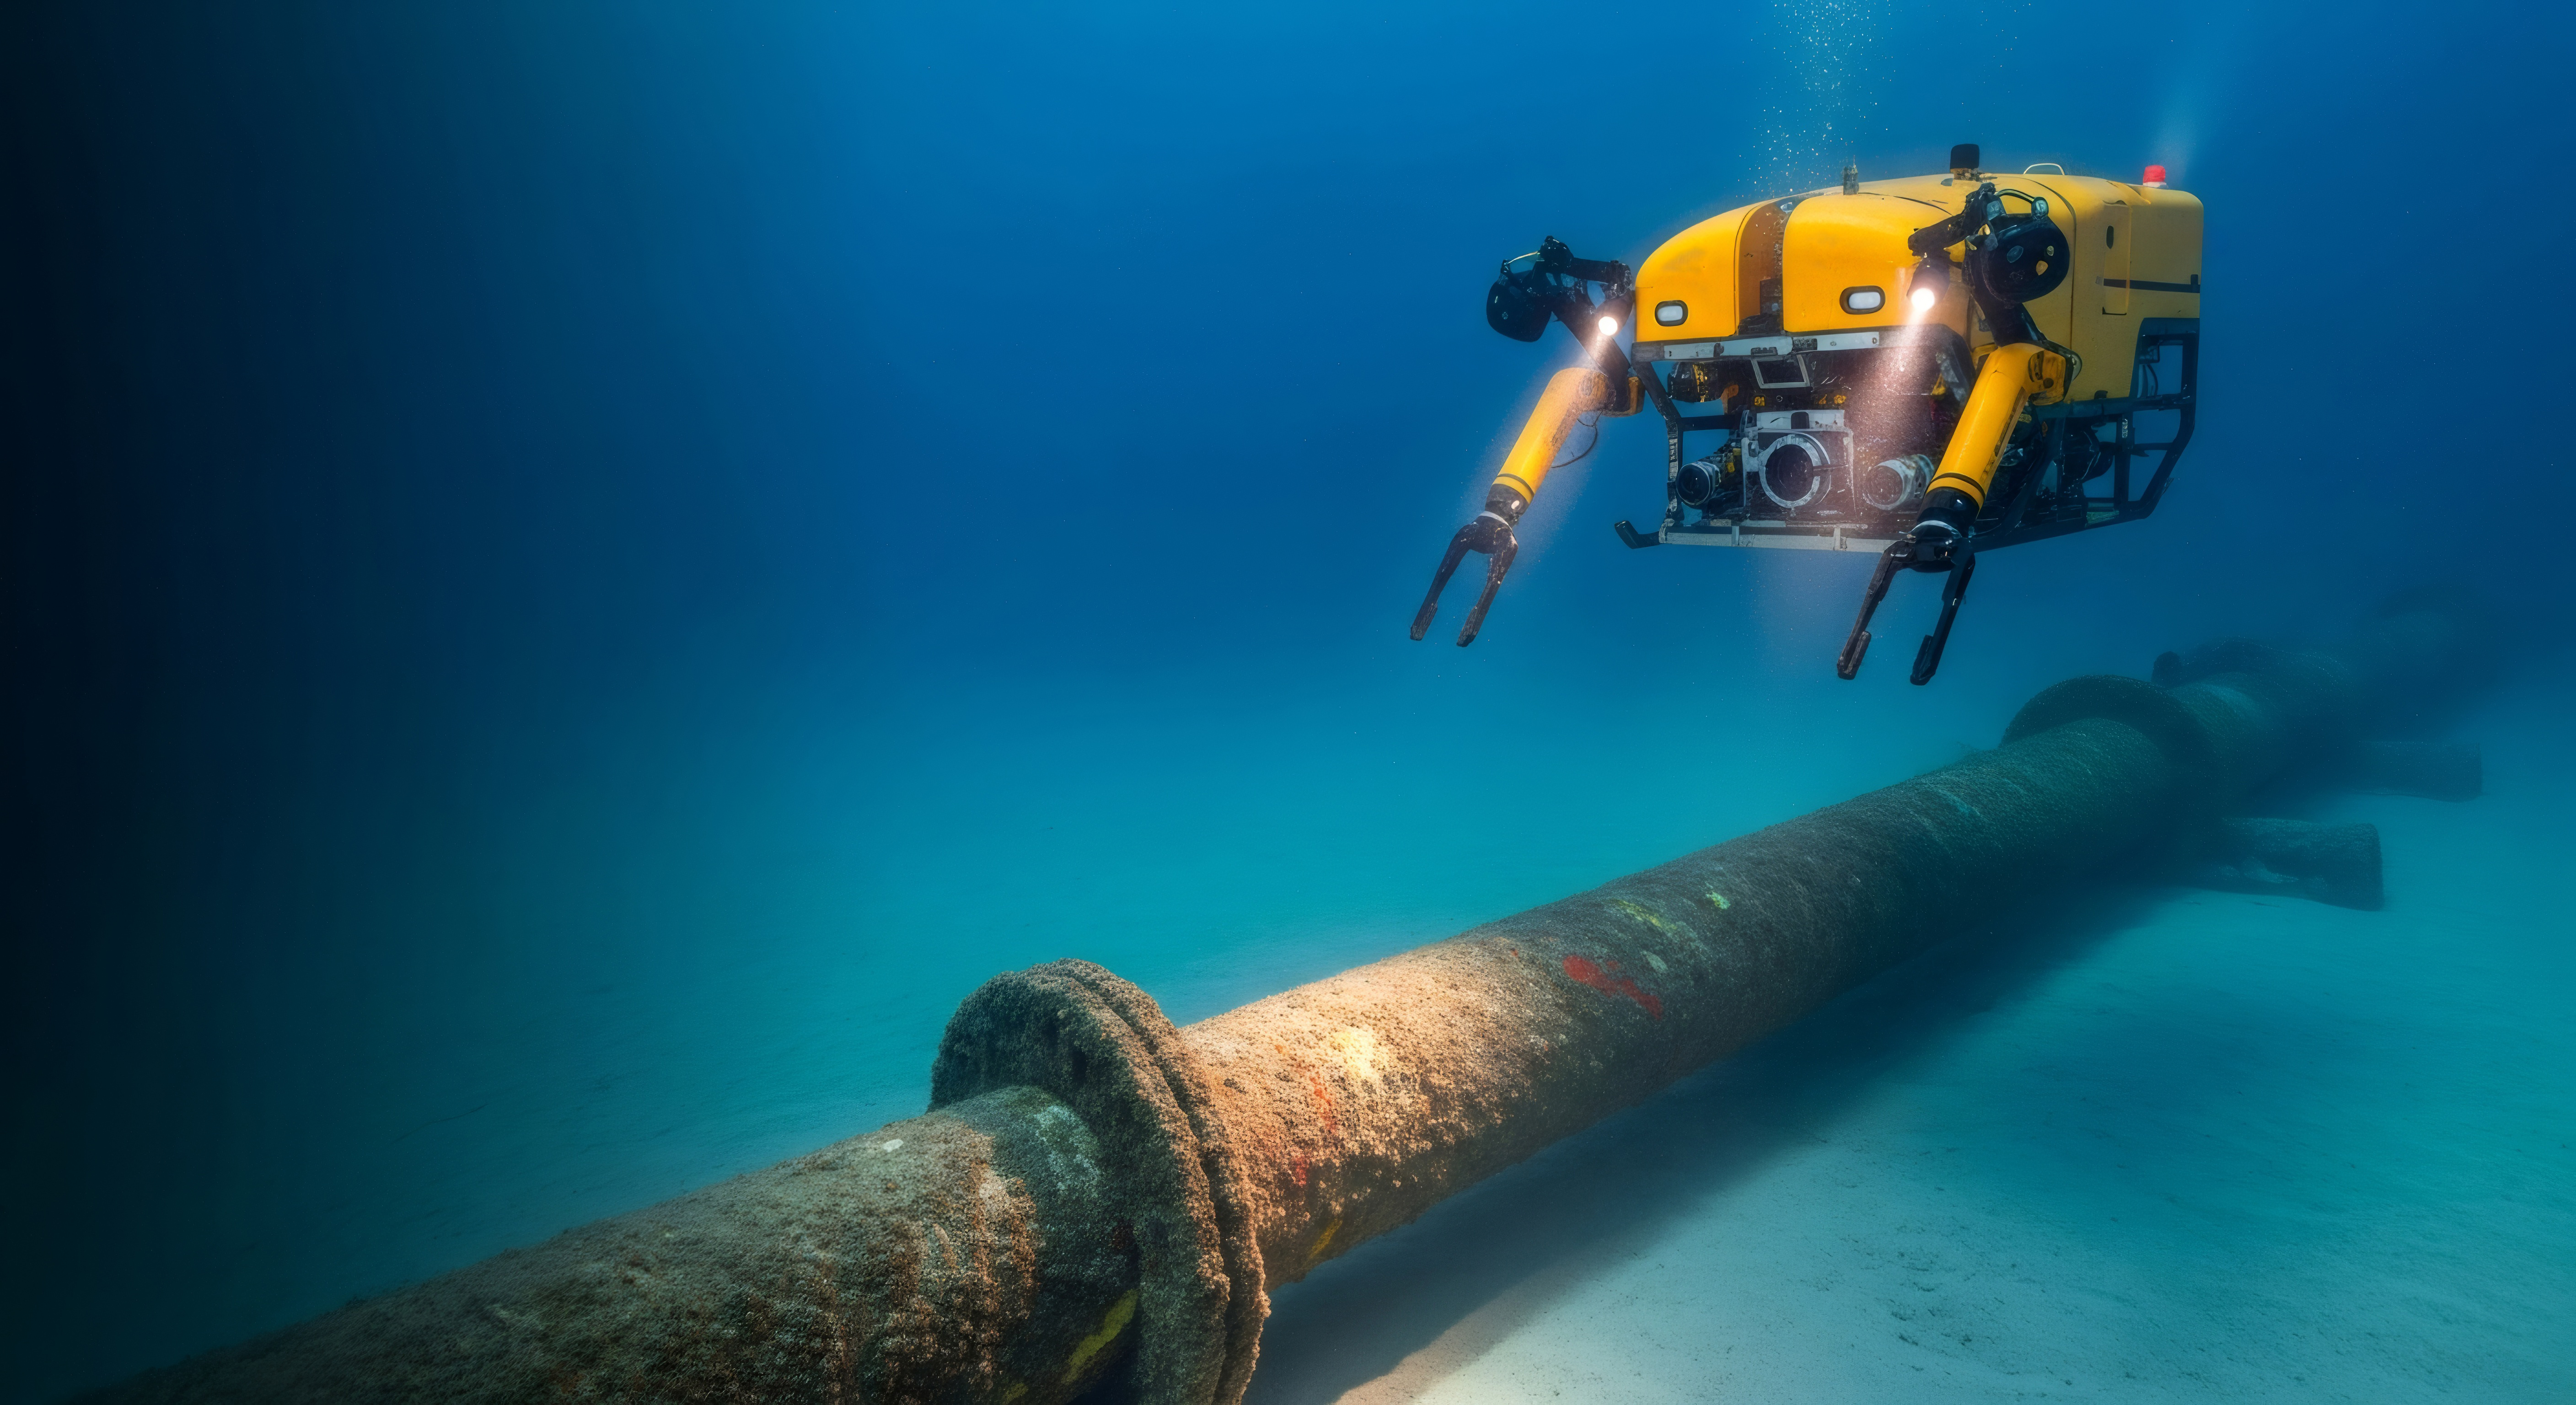
Industry-Grade Robotics
Reducing costs and protecting infrastructure through reliable robotics
From mission software to system integration
Where EVR Operates
Full-stack system integration — from operator requirements to hardware deployment
What We Deliver
Embedded systems and robotics solutions. Engineered for real-world operations.
Your mission context Your site deployment
LAYER 1 — EMBEDDED
Custom Embedded Linux Image
For your target hardware
- Vendor BSP as starting point (Jetson, Qualcomm, custom carrier)
- Sensors and peripherals integrated into the image
- Stripped to production size
- TensorRT runtime configured, GPU memory allocated
- Real-time scheduling tuned for ROS2 + inference coexistence
LAYER 2 — APPLICATION
Mission Software Architecture
Designed, implemented and validated on production hardware
- Mission state machine and behaviour architecture designed for your application
- Software component decomposition : clear interfaces, defined failure modes
- ROS2 as integration layer : nodes, topics, lifecycle management
- On-device inference integrated natively into the control loop
- MIL-SIL-HIL validation loop
The Integration Advantage
Your project needs both layers? → No integration overhead
- The image is built knowing exactly what the application needs
- The application is designed knowing exactly what the OS provides
- One person accountable for the full path from sensor to actuator
Platform Coverage
Hardware-Agnostic by Design
NVIDIA Jetson
Orin NX · AGX Orin
- Custom Yocto image on meta-tegra BSP
- Sensor integration, ROS2 + TensorRT coexistence
- Boot time optimisation, production-hardened
- PIL validation pipeline with Isaac Sim — demonstrated on Orin NX
Qualcomm Dragonwing
RB5 · IQ8 / IQ9
x86 + Axelera Metis
Industrial PC · European edge AI silicon
Same BSP methodology applied to each platform. Roadmap driven by client demand.
Platform recommendation is part of the engagement — if you haven't chosen your compute stack yet, that conversation happens before any code is written.
Industry Track Record
Proven excellence across aerospace, automotive, and railway—bringing mission-critical expertise to robotics
ACTIA RAILWAY
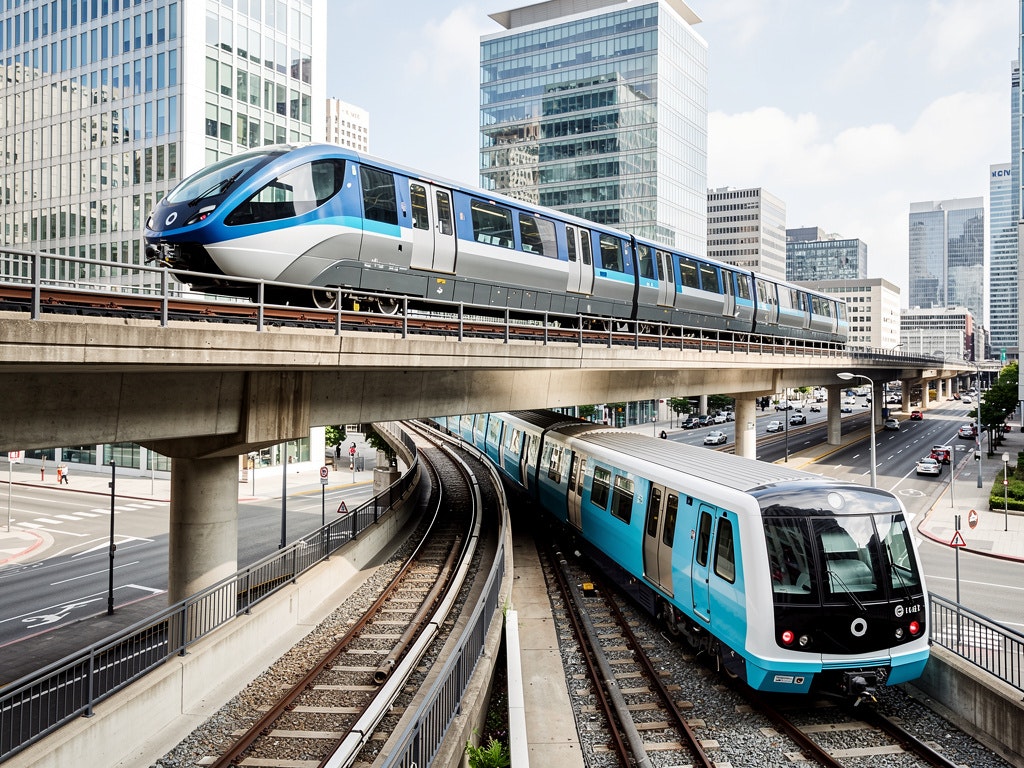
Subway Passenger Information System
Paris GPEL18 & Toulouse TISSEO C line Subways
System Roles:
- Solutions architect for metro communication system
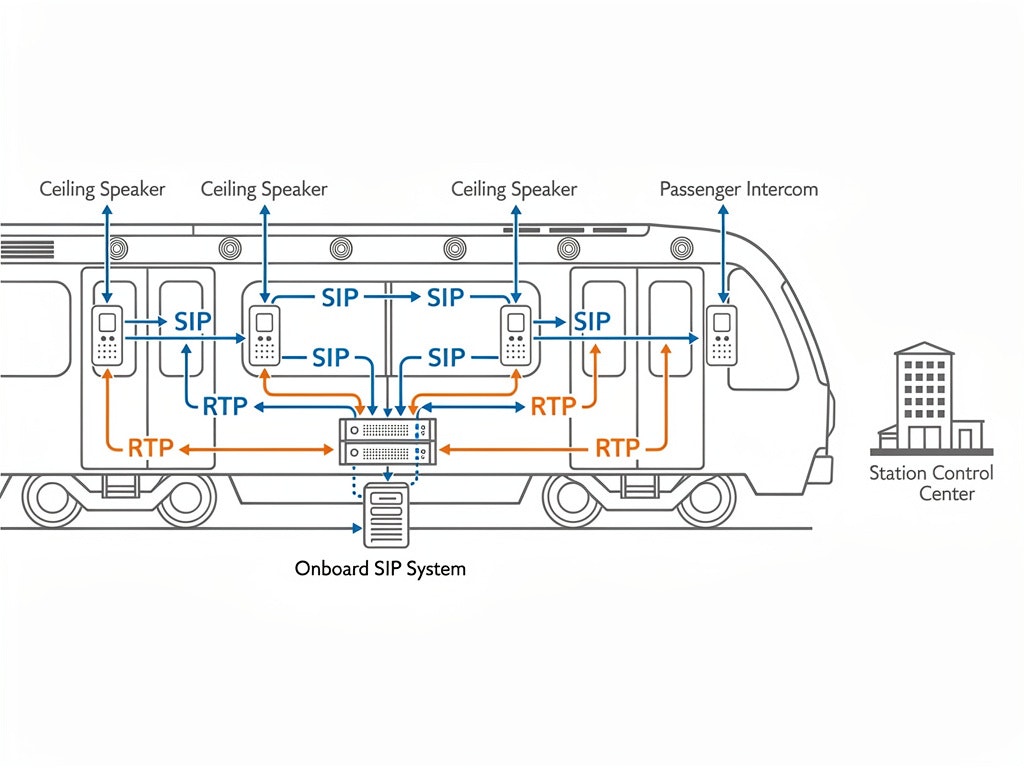
- VoIP communication stack development (PJSIP/Yocto)
- Software integration lead at Alstom facilities
- Multi-vendor system integration
Challenge:
Mission-critical passenger information system for 24/7 metro operations—real-time audio/video communication, emergency systems, multi-equipment synchronization, railway safety compliance (SIL0), and heterogeneous hardware integration.
Delivered:
Complete distributed communication platform: master equipment coordinator, VoIP telephony system, cross-equipment synchronization, in-cabin audio streaming, and embedded Linux platform (Yocto/C++). Successfully deployed in Paris and Toulouse metro lines.
Impact:
✓ Distributed system architecture applicable to multi-robot coordination ✓ Real-time communication expertise for robot fleet management ✓ Embedded Linux platform mastery transferable to autonomous systems ✓ Railway safety standards (SIL0) demonstrate validation rigor ✓ Production deployment in mission-critical infrastructure proven
CONTINENTAL
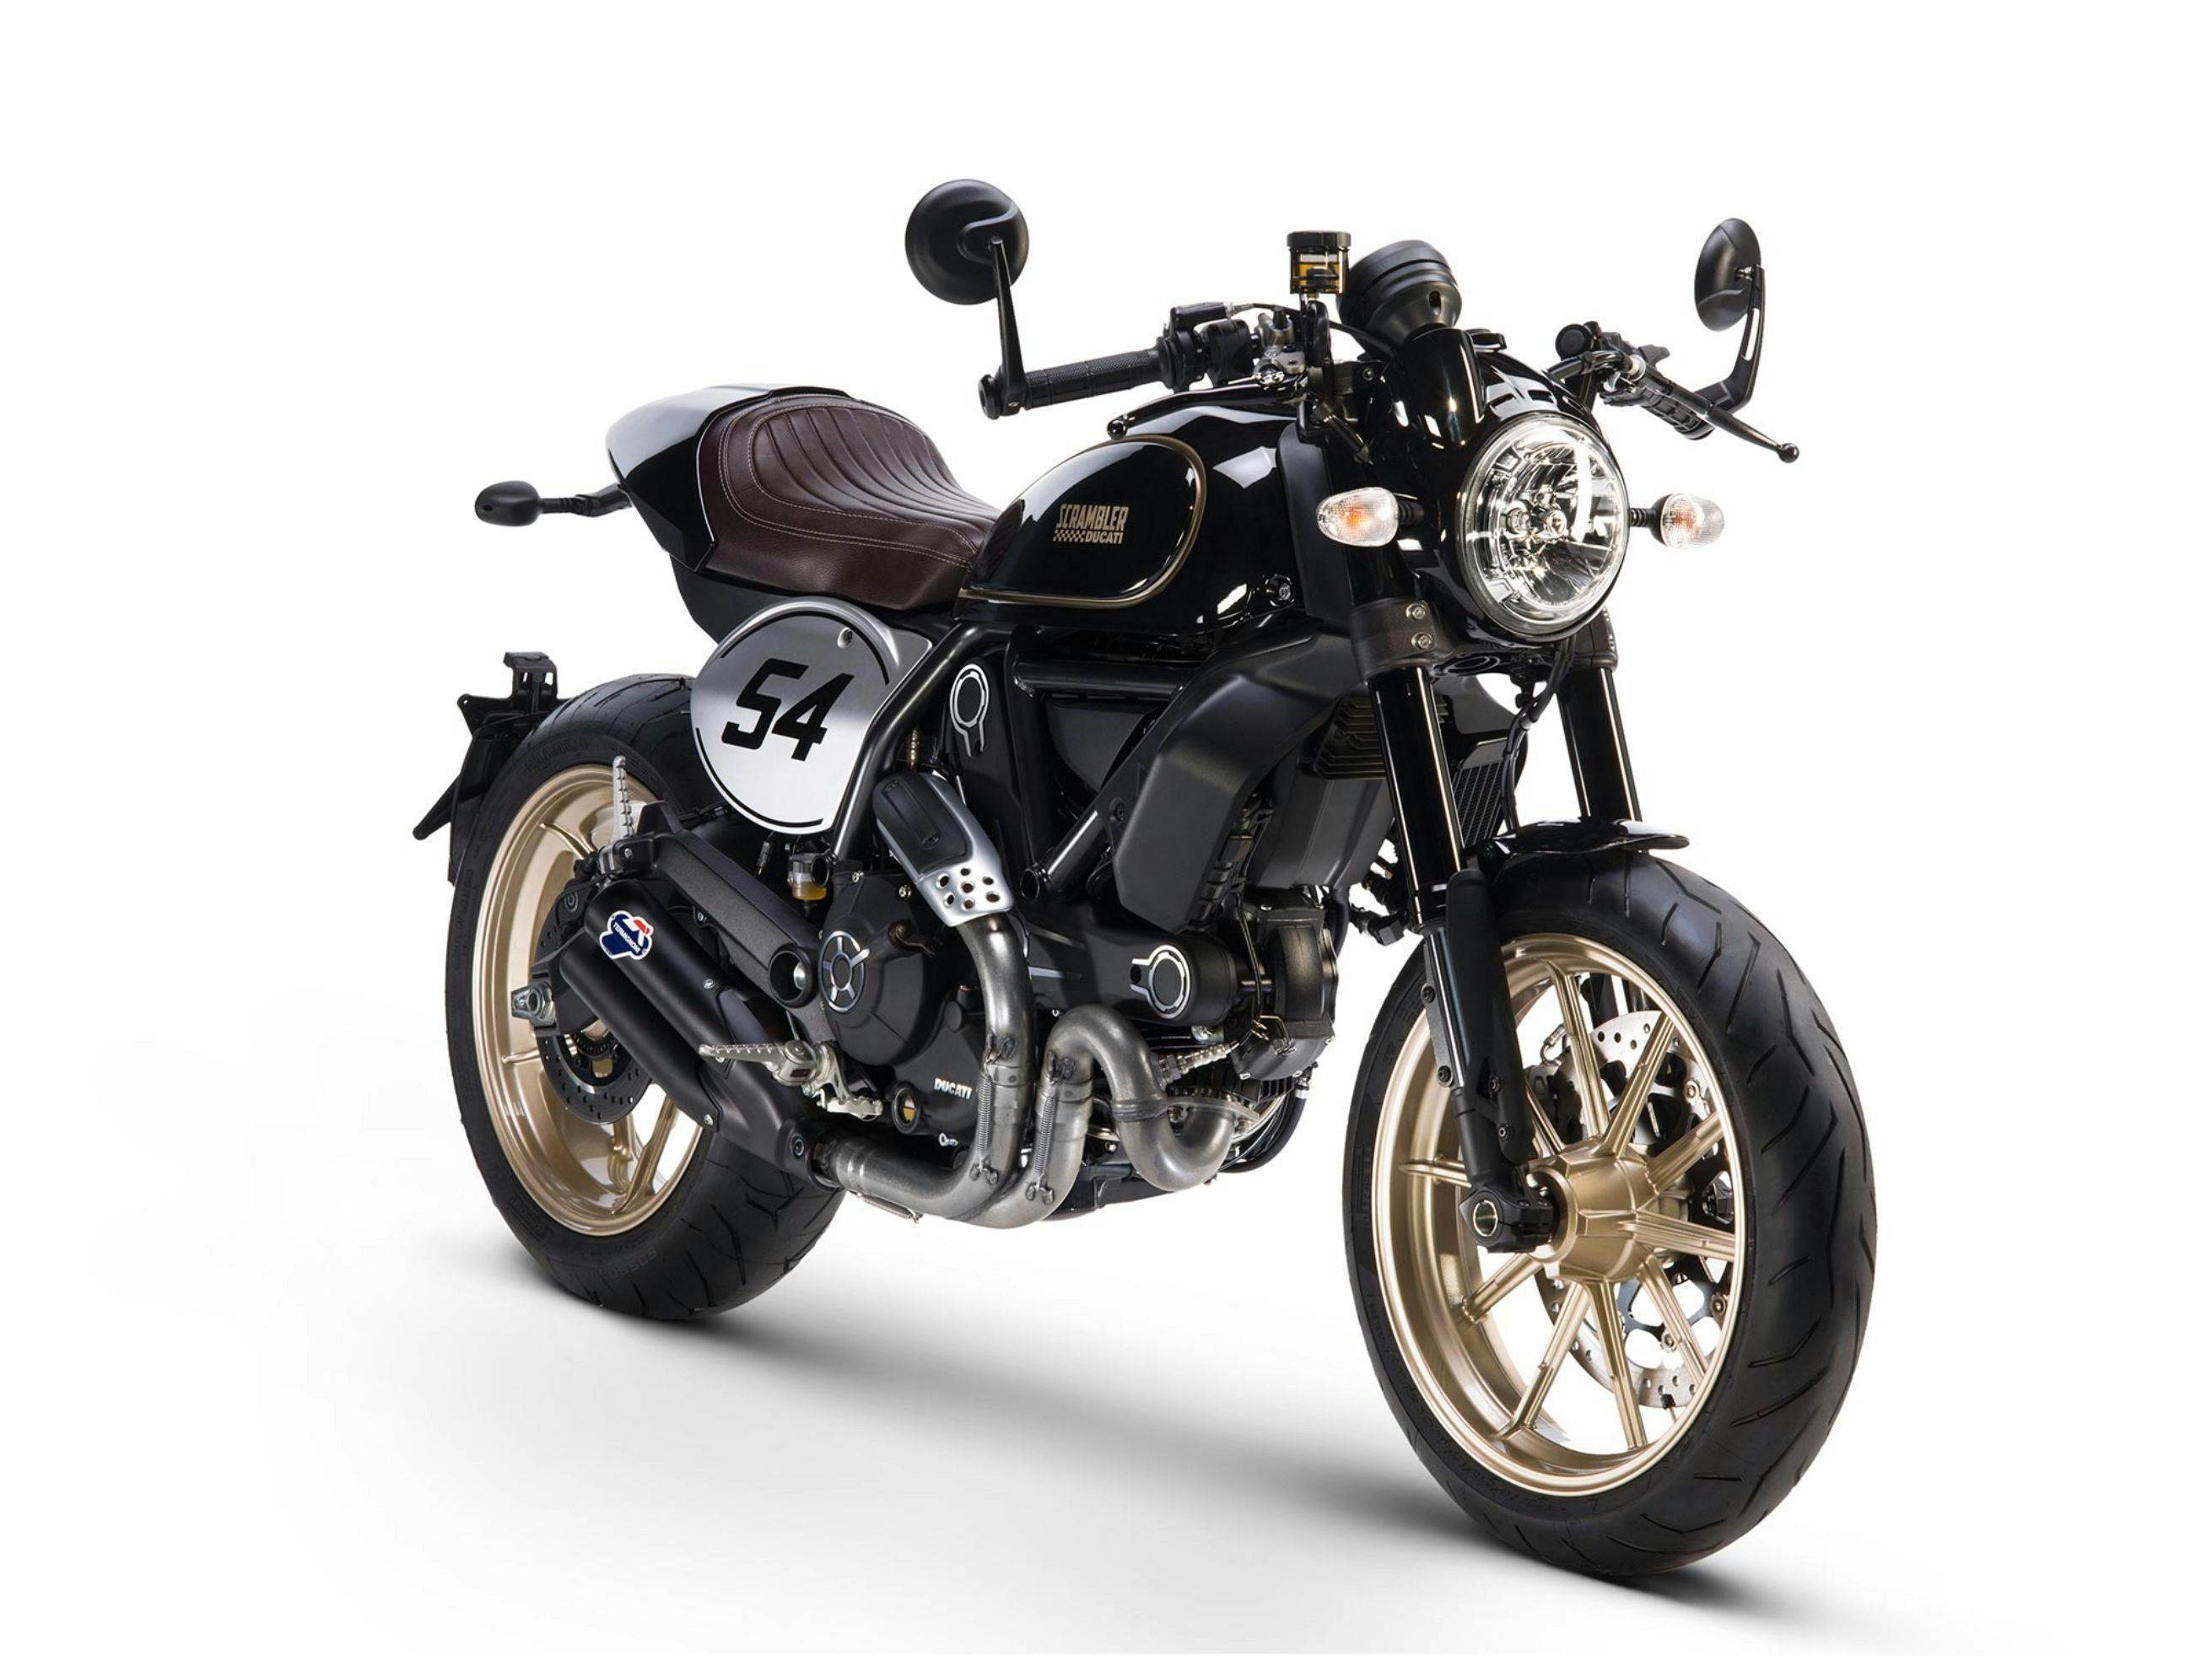
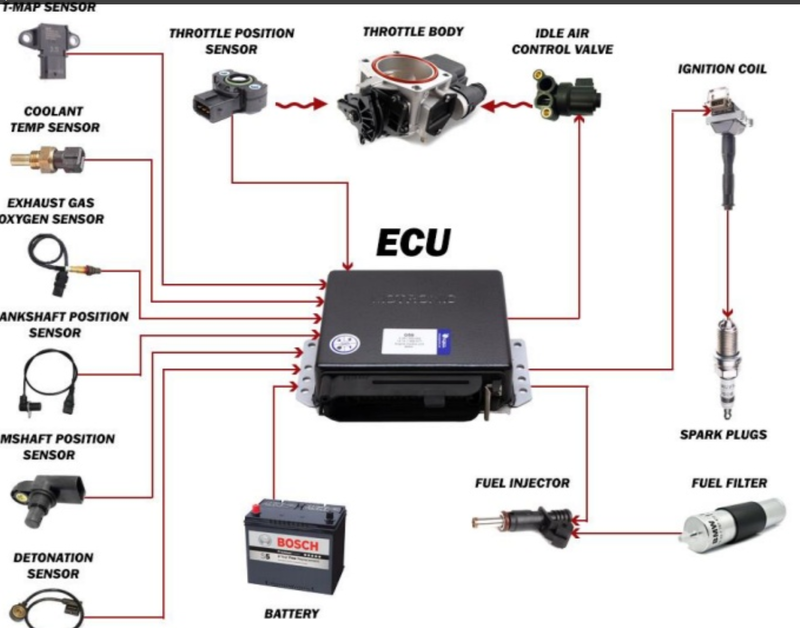
Powertrain - Engine Control Unit
Vehicle: Ducati & Royal Enfield
System Roles:
- Full development cycle management
- Cross-functional team leadership
- Production deployment and validation
Challenge:
Breakthrough engine control strategy for high-performance motorcycle - balancing performance, emissions compliance, and production constraints.
Delivered:
Led 5-person team through complete V-cycle development of ECU control software. Managed algorithm design (Matlab/Simulink), autocoding, sensor/actuator interfaces, CAN network integration, and final vehicle validation. Successfully deployed to production.
Impact:
Demonstrated full lifecycle project leadership and real-time control expertise in automotive environment. Experience with production deployment, validation methodologies, and cross-functional coordination.
LIEBHERR AEROSPACE
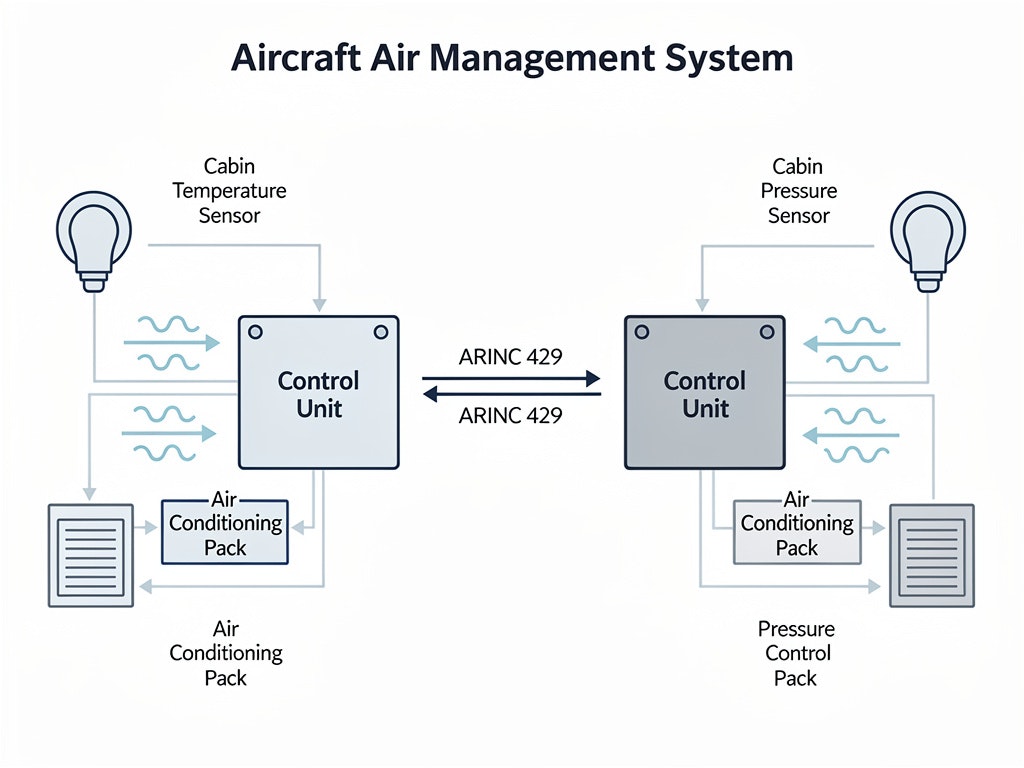
Aircraft Air System Control
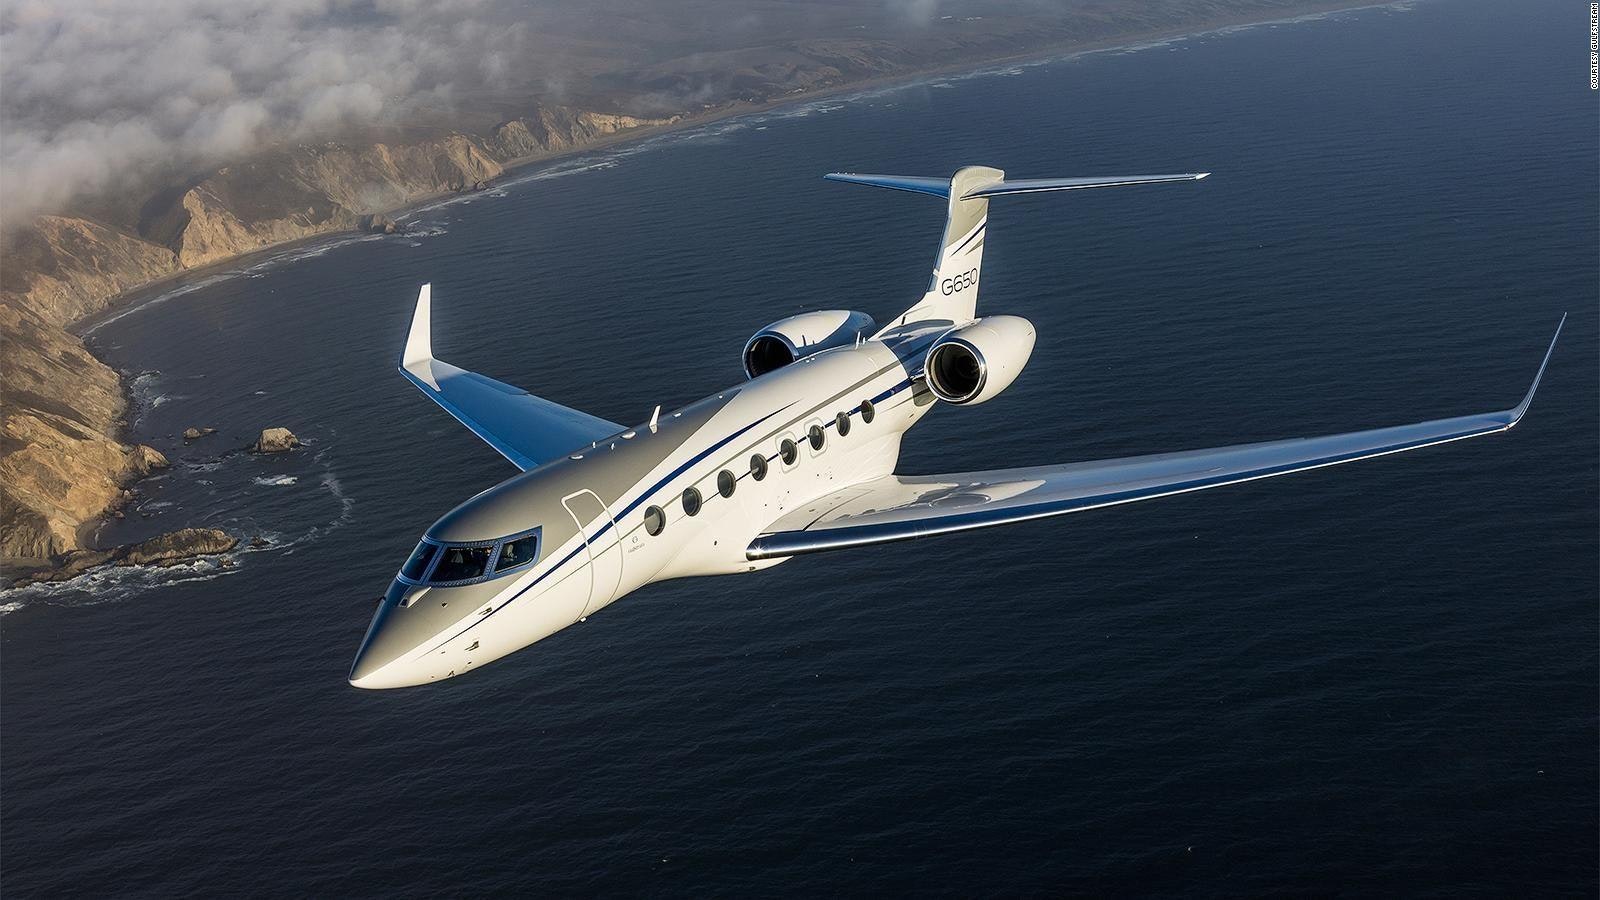
Vehicle: Bombardier Global 7000 Jet
System Roles:
- DO-178C compliance and certification
- Functional HIL testing architecture
- System integration and validation
Challenge:
Safety-critical air management system for business jets requiring highest level of software certification (DAL A) and integration with Airbus platforms.
Delivered:
Designed software functions for aerospace air control systems within DO-178C DAL A framework. Developed functional Hardware-in-the-Loop (HIL) test architecture for validation. Coordinated multi-supplier integration for Bombardier G7000 Jet platform.
Impact:
Proved ability to work in most demanding safety-critical environment with rigorous verification and validation processes. Experience directly applicable to safety-critical robotics in industrial and outdoor environments.
Open-Source ROS2 = Safe Cost Reduction
We leverage the battle-tested ROS2 ecosystem + full-stack expertise.
Used by Boston Dynamics, FANUC, Figure AI
Cost Reduction
Focus on custom needs
Battle-Tested
Used by 1,250+ companies worldwide
Full-Stack
Algorithm → Hardware
Portfolio & Samples
Solution samples and project demonstrations
Sample Project
Available Soon
Meet Mickael Evrard
Where Aerospace Rigor Meets Modern Robotics
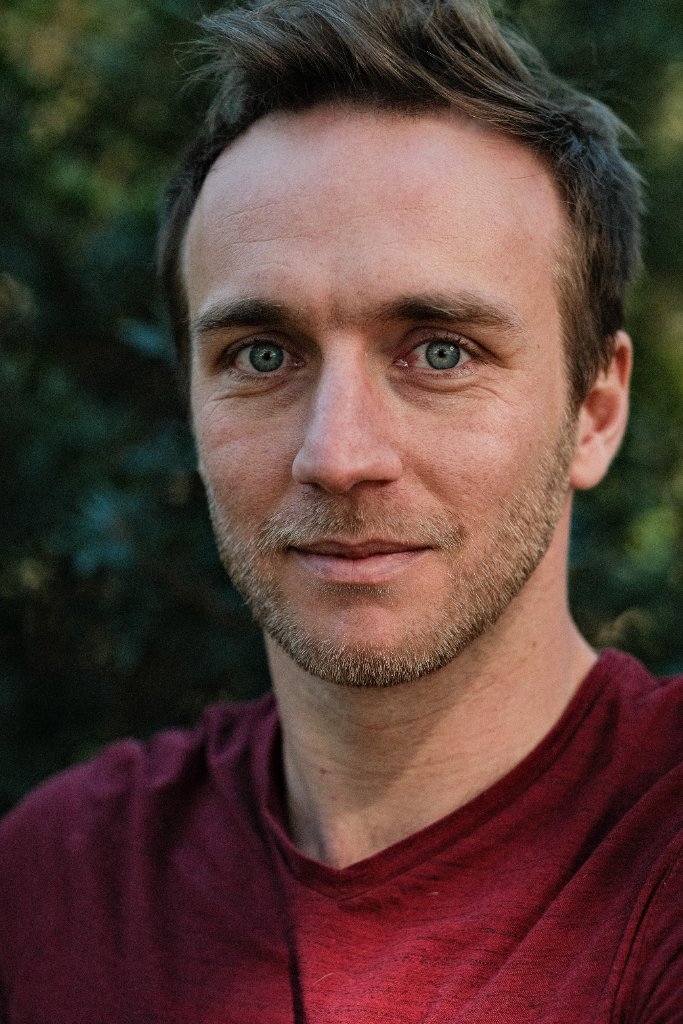
Mickael Evrard
Founder & Autonomous Navigation Engineer
7+ years delivering safety-critical embedded systems for Airbus, Renault, and Ducati. Master's degree in Automatic Control and Mechatronics from ENSEIRB-MATMECA.
Now bringing industry-grade validation and embedded systems expertise to RO2-based robotics navigation—combining proven methodologies with cutting-edge technology.
Currently completing The Construct's 1000-hour Robotics Developer Masterclass, specializing in autonomous mobile robot for industrial and outdoor applications.
Key Competencies
Let's Build Something Exceptional
Get in touch to discuss your project.
Location
Europe & Remote Worldwide
Start Your Project Today
Whether you need embedded systems development, robotics control, or full lifecycle project management, EVR Consulting delivers results.